A. Paris

Portfolio · last updated Oct 2026

Axel Paris

Engineering student at Centrale Lille, majoring in embedded and cyber-physical systems. I build robots end to end: 3D-printed parts, electronics, ROS 2 / Gazebo simulation and the control code that ties it all together.

Looking for a 6-month robotics internship starting April 2027.

Axel at the workbench

Projects

01

Sorting moving objects with a soft robot

Ongoing
Context
Integration project · Compliance Robotics / INRIA DEFROST
Period
Sept 2026 → Mar 2027
Tools
Python, computer vision, motion planning

The project is built as a series of milestones, each one a live demo on the robot. We only move on once the previous one works: locate still objects on the conveyor, track them and predict their position, move the gripper to a still object, then follow, intercept and grab a moving one, and finally sort it by colour.

Constraints: the system has to be reliable and repeatable, and stay within the robot's joint limits and motor heating. Success rate will be measured over test series and compared with the state of the art.

Results to come.
02

French Robotics Cup — robot simulation

Context
ARCL, Centrale Lille robotics club · software team lead
Date
2026
Tools
ROS 2, Gazebo, Raspberry Pi

A ROS 2 / Gazebo simulation of our competition robot, used to test localisation and trajectory following before running anything on the real hardware (Raspberry Pi).

The point was to unblock the software team: with a simulated robot, we could develop everything downstream of localisation (trajectory following, game strategy…) without waiting for the mechanical and electronics teams to deliver the real robot.

Localization in Gazebo
Trajectory in Gazebo
Trajectory with obstacle avoidance in Gazebo
Trajectory with obstacle avoidance and noise around in Gazebo
03

7-DOF robotic arm in simulation

Context
Personal project
Date
Sept 2026
Tools
ROS 2, Gazebo, C++

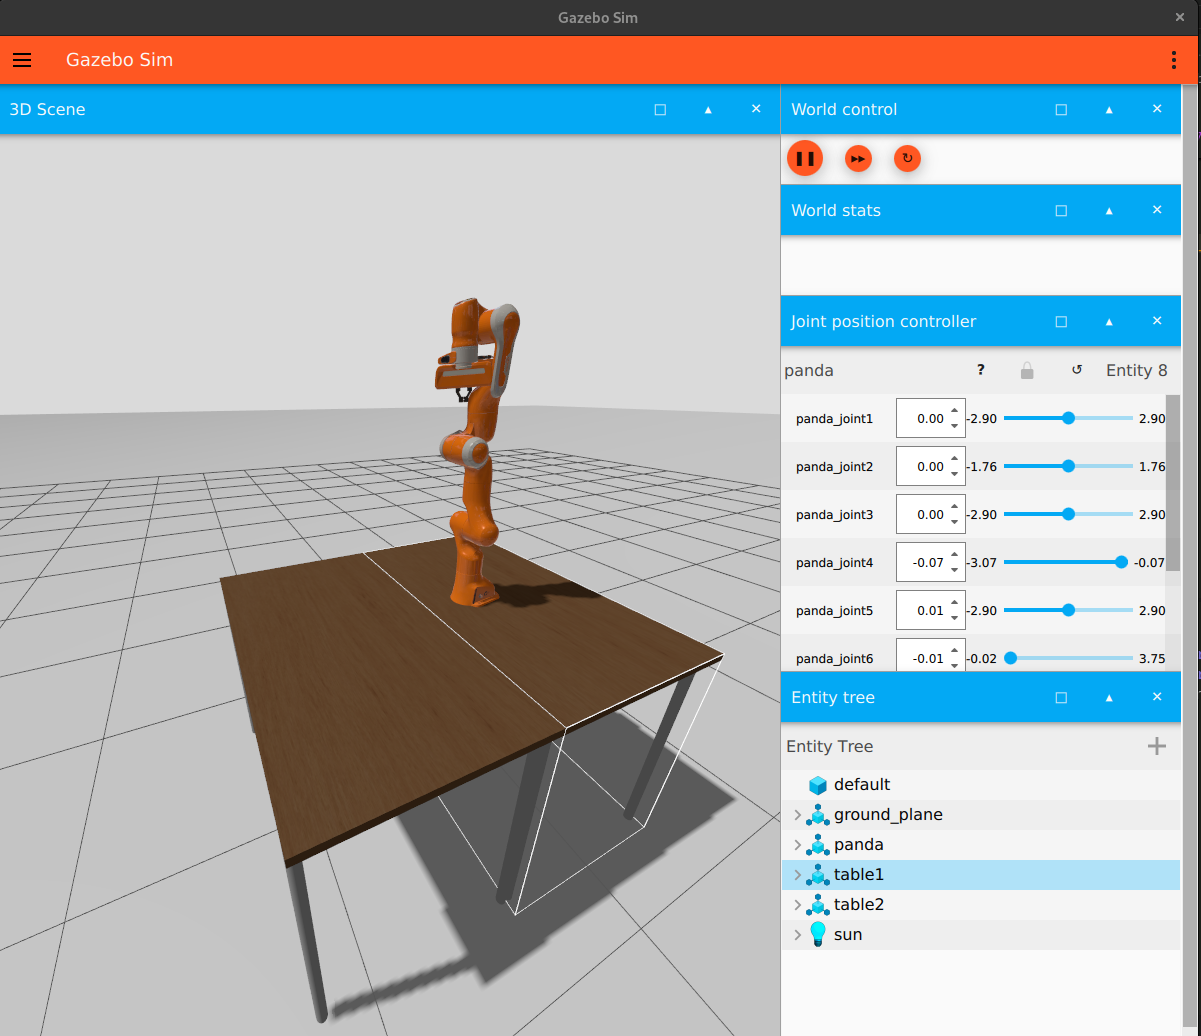
A Franka Panda arm uses a depth camera to find coloured cubes on a table. It picks them up and stacks them in a chosen order. Before grasping, the gripper rotates to match each cube's angle. If a cube is blocked by another one, the arm moves that cube out of the way first.

I wrote the inverse kinematics (damped least squares on the full pose). The motion is tracked by a model predictive controller (MPC) running at 100 Hz.

7-DOF arm in Gazebo
Gazebo view
Pose tracking in Gazebo
04

Robotic hand

Context
Personal project
Date
Sept 2026
Tools
CAD, 3D printing, control

Mechanical design and control of a robotic hand.

Five fingers actuated by fishing-line tendons, each pulled by a Miuzei servo. An ESP32 drives the servos, and the commands come from a Python program using OpenCV.

Demo video
05

City guessing game

Context
Personal project
Date
Aug 2026
Tools
JavaScript, PHP, HTML/CSS

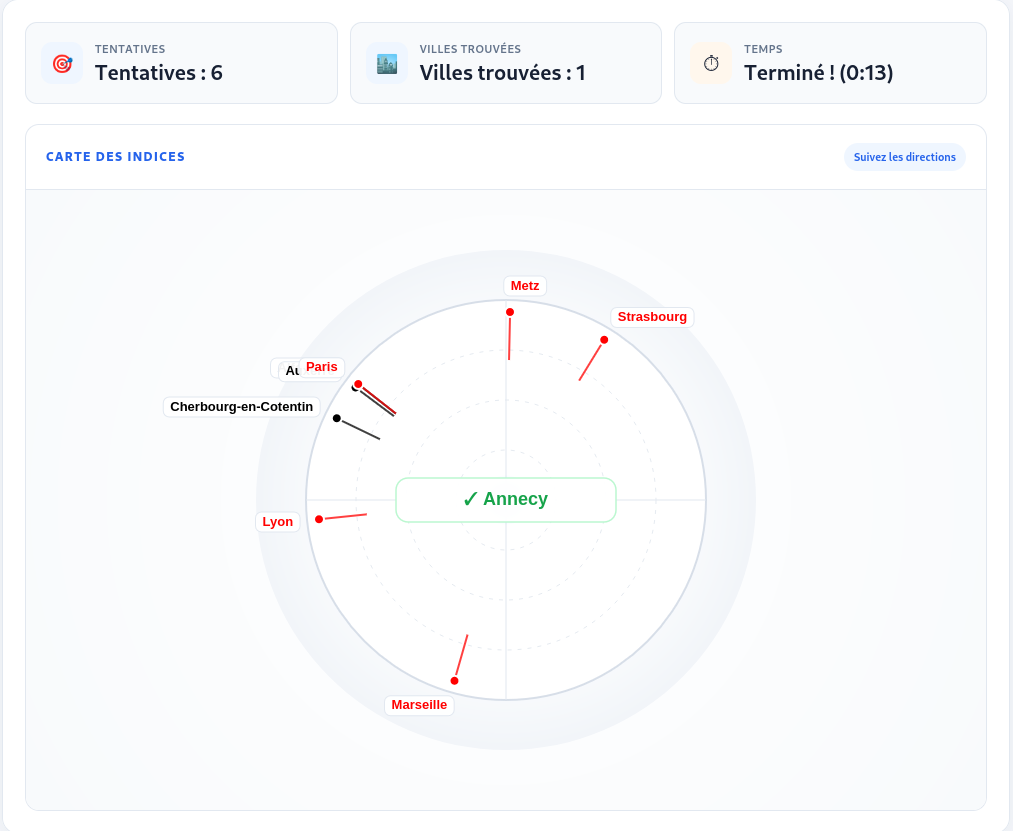
A small web game: you have to find a hidden city. Each guess tells you which direction the target lies from the city you entered, so you close in on it step by step.

I'd played a game like this online, couldn't find it again, so I rebuilt it myself.

City guessing game screenshot
A game in progress
06

Self-balancing robot

Context
Personal project
Date
Aug 2026
Tools
Control systems, embedded electronics

A two-wheeled robot that stays upright on its own. Most of the work went into the control loop.

Sensor (IMU), controller (PID), loop rate, tuning.

07

3-DOF robotic arm

Context
Personal project
Date
May 2026
Tools
ROS 2, Gazebo, 3D printing

An arm designed and built from scratch: mechanical parts, simulation, then control through ROS 2.

Actuators, sim-to-real link

Assembled arm
08

Remote-controlled car

Context
Personal project
Date
Aug 2025
Tools
Electronics, programming, 3D printing

My first hands-on build: a small 3D-printed car with its own electronics and code. The goal was simply to learn, by wiring, programming and printing everything myself. It's where most of my later projects started.

09

Protomia — 3D reconstruction for surgery

Context
Centrale Lille project
Period
Sept 2024 → Feb 2026
Tools
Angular, Node.js, photogrammetry

A web app that turns 2D photographs into 3D models for surgical use.

Background

Experience

  • 2026–27
    Compliance Robotics / INRIA DEFROSTIntegration project — deformable robot
  • 2025–26
    Lille University HospitalHearing test software for clinical use (Junior Enterprise)
  • 2025–26
    Bunqer, ParisInternship, then freelance — automated multilingual AI dubbing
  • 2025
    ETIS-Lab, CergyInternship — monitoring interface for compute servers

Education

  • 2024–27
    École Centrale de LilleEngineering degree — Embedded & Cyber-Physical Systems · GPA 3.8/4
  • 2024–25
    Université de LilleBSc Mathematics — valedictorian, highest honours
  • 2022–24
    Lycée Kléber, StrasbourgPreparatory classes MP2I / MPI*

What I work with

Robotics ROS 2, Gazebo, control systems, KiCad · Embedded C, Raspberry Pi, GPIO, Linux, cross-compilation · Software Python, C++, Git, Docker

Contact

An internship, a project, a question about a robot? Drop me a line.